
Part geometry
CAD models, 3D scanning and recognition of parts from a library provide a common starting point for process preparation.

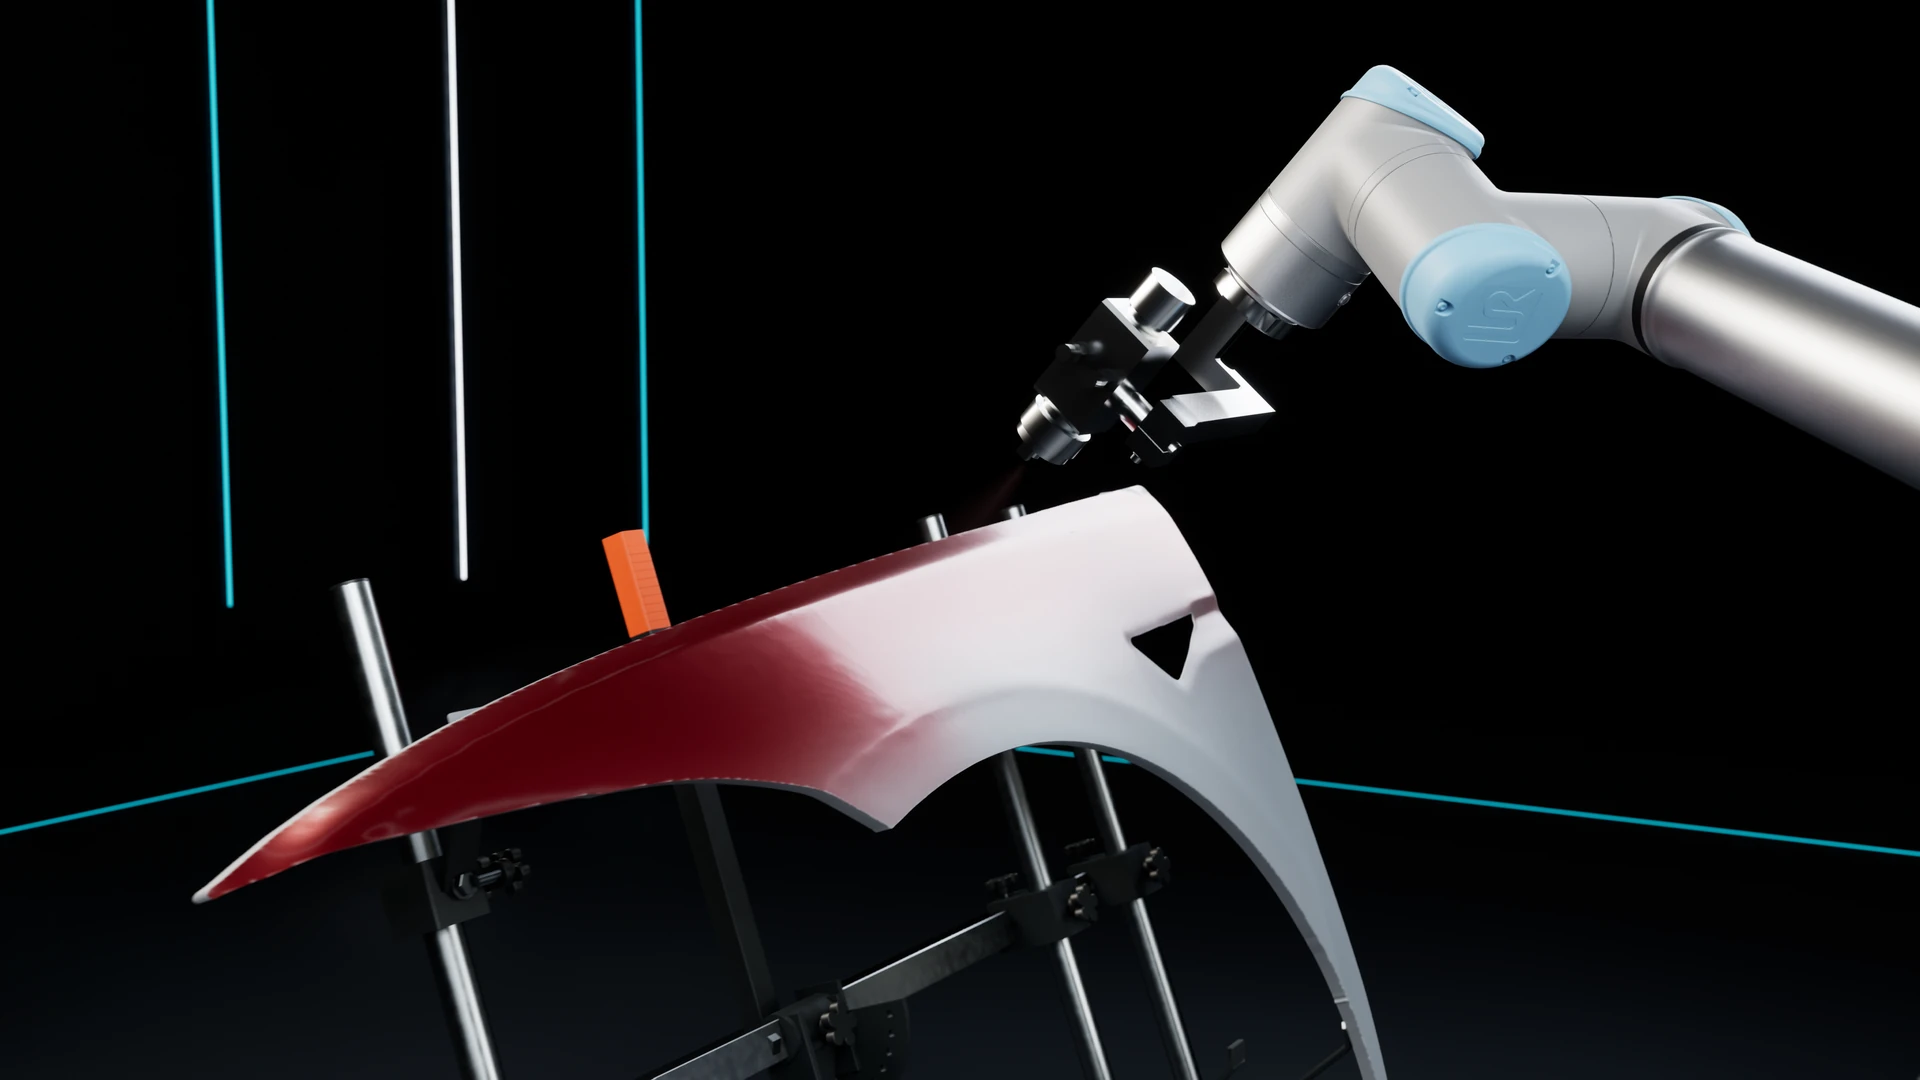
We build SCAN2SPRAY and train AI models that learn to carry out the painting process. We combine 3D geometry, motion planning and coating simulation so that robot decisions are informed by part shape, spray characteristics and process requirements.


In robotic painting, the path, applicator motion and quantity of deposited material form a single process. SCAN2SPRAY lets you consider them together: prepare the part, define surfaces, plan passes and evaluate the predicted coating on a 3D model.

CAD models, 3D scanning and recognition of parts from a library provide a common starting point for process preparation.
Paths, applicator orientation, spray parameters and successive layers are evaluated in the context of the complete cell.
SI_Path focuses on learning from painting demonstrations, with model behaviour evaluated through robot motion and the predicted coating.

We train models to make motion and spray decisions in a simulation environment. The surface state, target coating and robot constraints define the task. Each run provides data on how the selected strategy affects coverage, film thickness and motion execution.
Further SI_Path development centres on NVIDIA Isaac Lab and adapting NVIDIA Isaac GR00T models to painting tasks, with coating quality as a key evaluation criterion.

From scanning an automotive body panel, through surface reconstruction and planning, to spray simulation. Our presentation materials also show single-colour coatings, multi-stage finishes and the organisation of a robotic painting line.
We are open to collaboration with manufacturers of robots, applicators, coating materials and production systems. We combine software, process models and robotic integrations in solutions tailored to a specific application.
We welcome industrial partners and investors interested in AI for painting automation.
PRISMATEC CONTROL Basic, CONTROL2 and SmartBooth cover booth control, recipes, installation monitoring and paint shop operations. The software can be supplied with a control cabinet and equipment integration.

Project updates and perspectives on robotic painting.
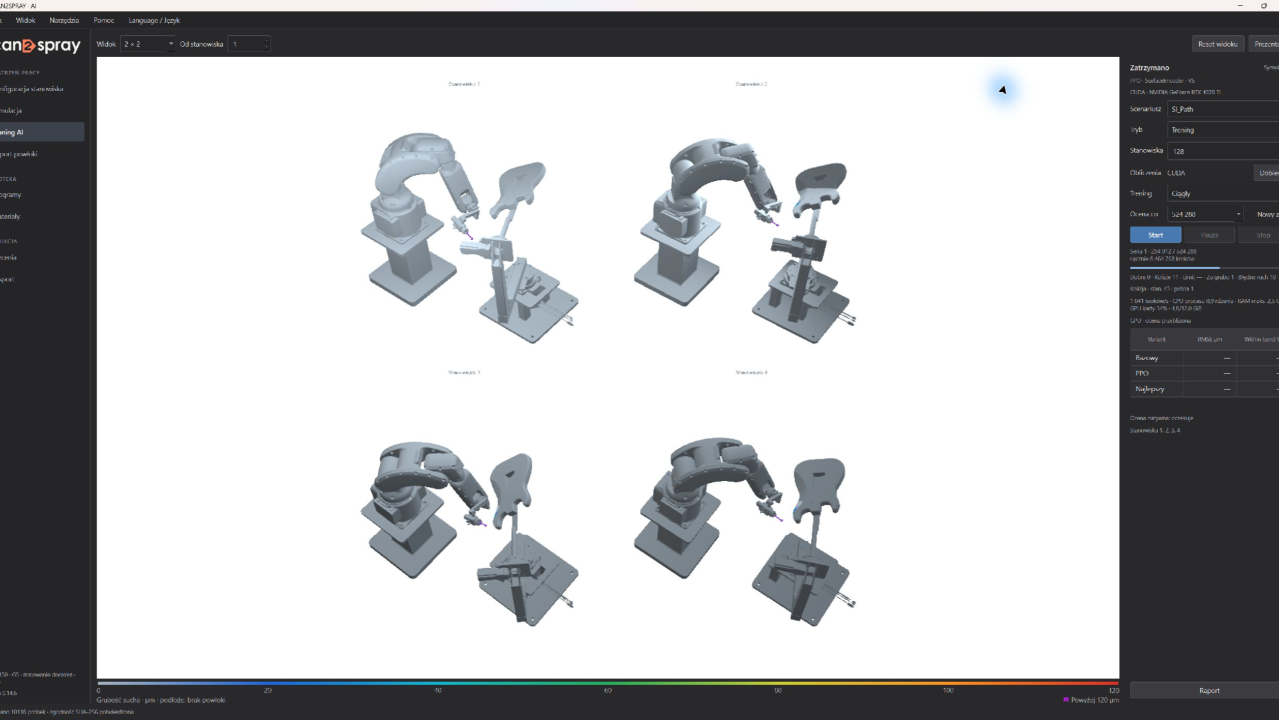
How SI_Path combines learning from engineering demonstrations, practice in virtual workcells and independent checks of robot motion and coating.
Read on LinkedIn ↗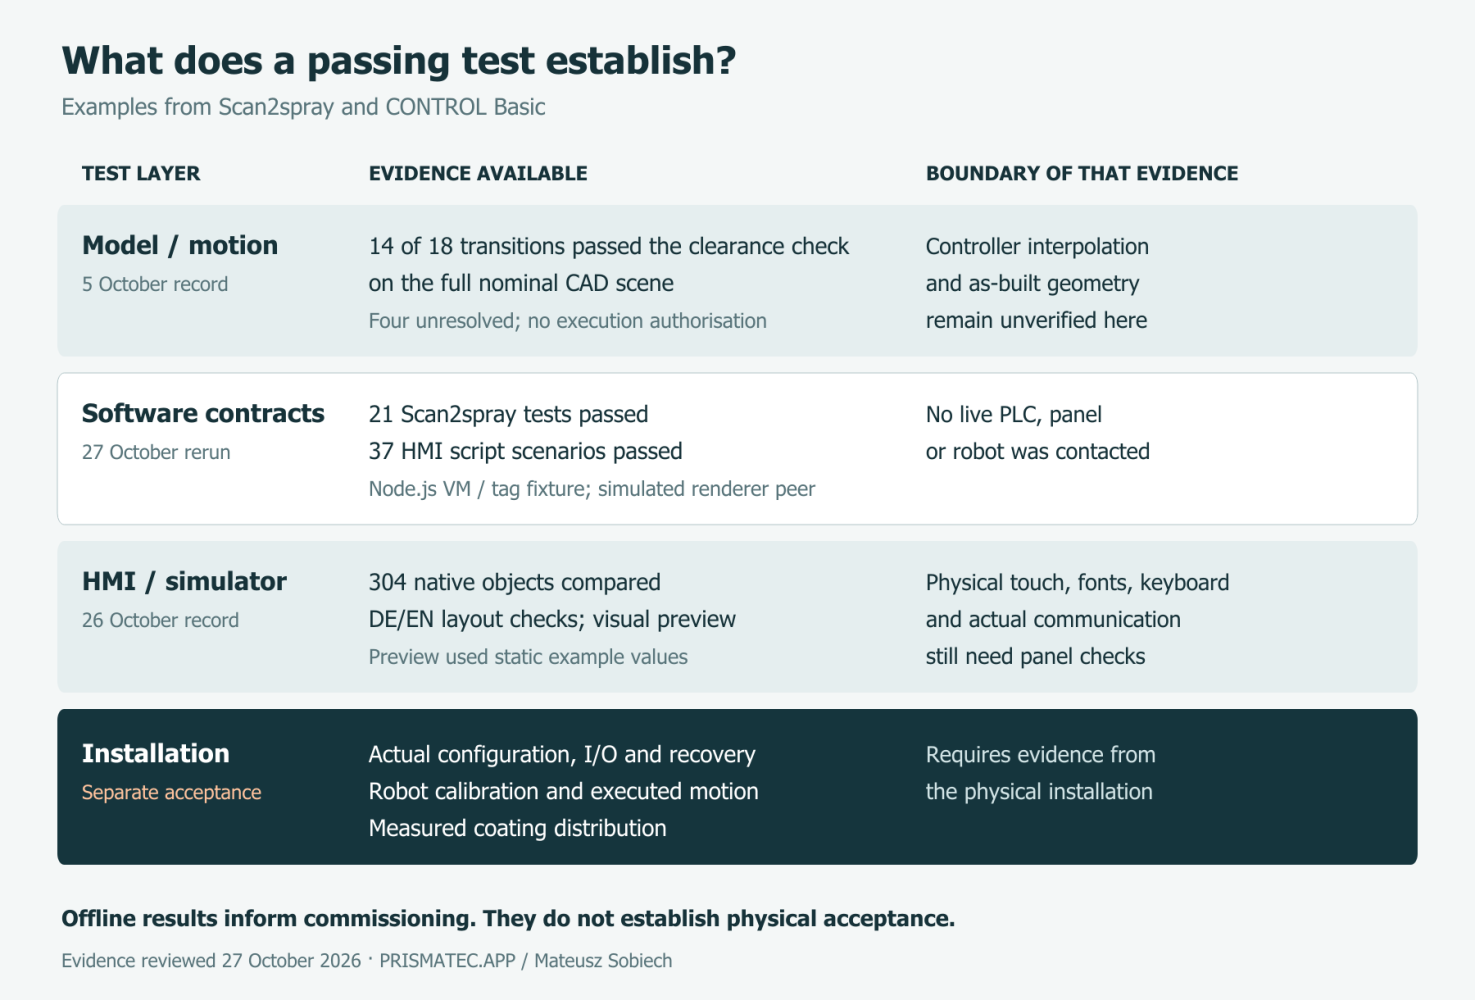
Configuration checks, PLC–HMI readback and communication tests in Scan2spray and CONTROL Basic, with a clear account of the verification still needed on the installation.
Read on LinkedIn ↗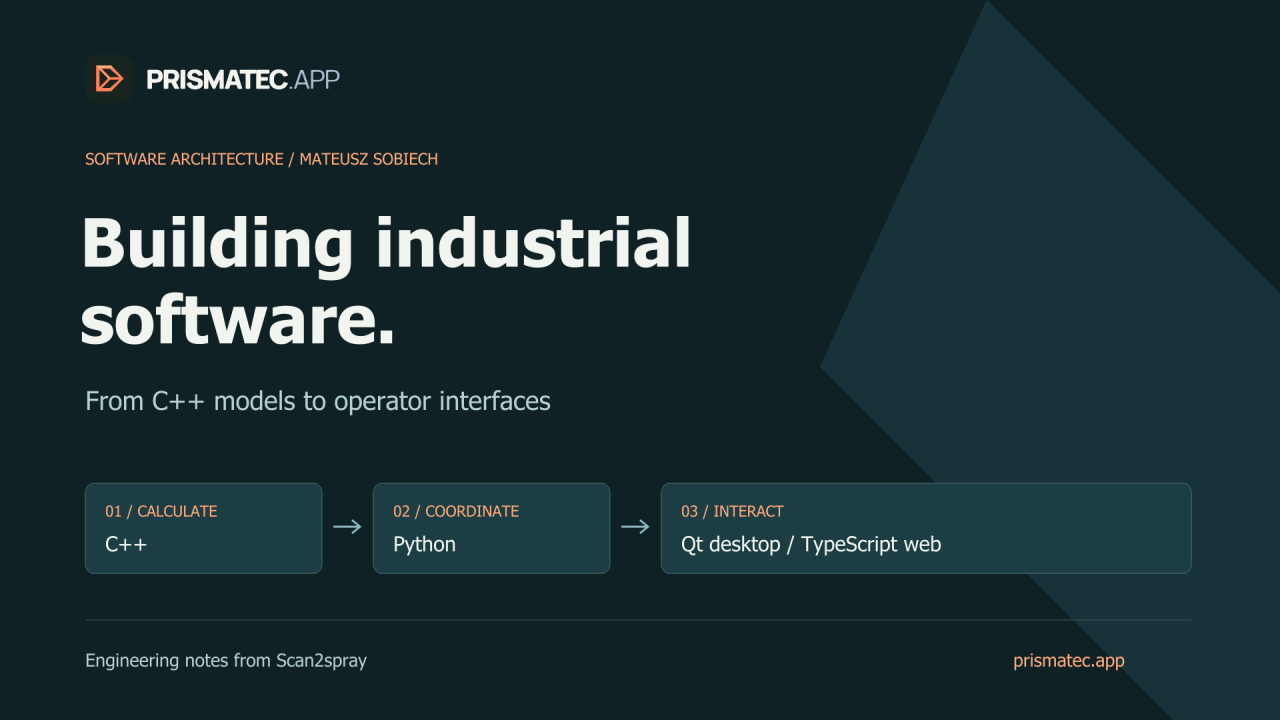
The roles of C++, Python, Qt and TypeScript in Scan2spray, from calculation and workflow to operator interfaces and checks that keep saved results tied to their inputs.
Read on LinkedIn ↗Tell us what parts you paint, what equipment you use and what result you want to achieve. We will define the scope of a technology demonstration, joint testing or integration.
contact@prismatec.app

